Error handling: Motor power OFF.
Error reset: Possible.
Description: The difference in encoder values between controller power OFF and the next controller power ON exceeds the abnormal encoder deviation range at startup set in auxiliary function 0504. This error is detected by the AS software.
This value is normally set to 2.0 degrees for each rotary axis. Setting it to 0.0 degrees disables detection of this fault. Setting it too low may cause this error whenever the controller power is turned ON, even when no abnormality exists.
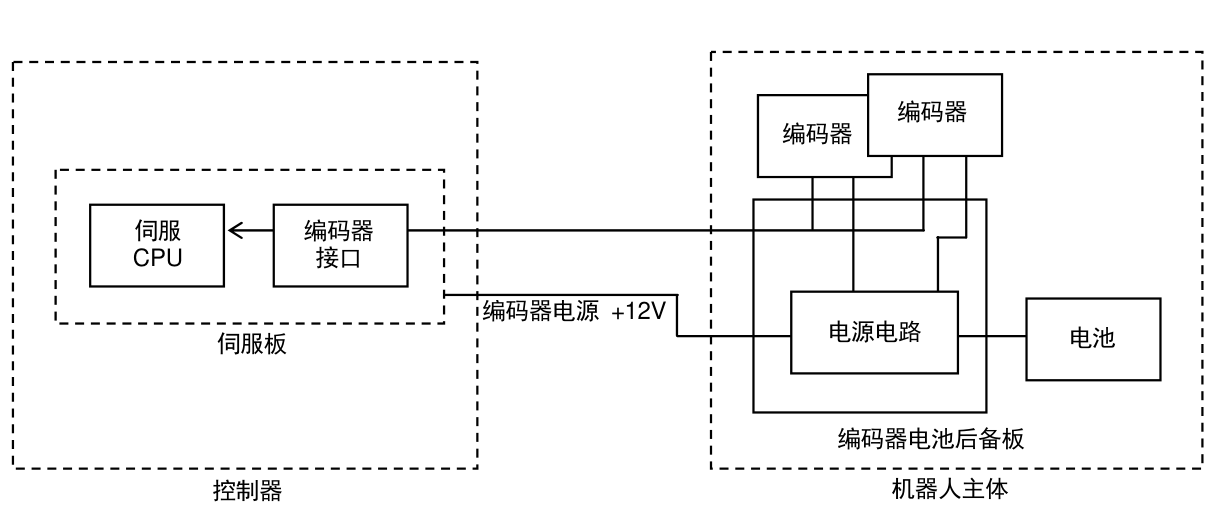
Encoder
Encoder
Servo
Encoder
CPU
Interface
Encoder power supply +12V
Power supply circuit
Battery
Servo board
Encoder battery backup board
Robot main body
Controller
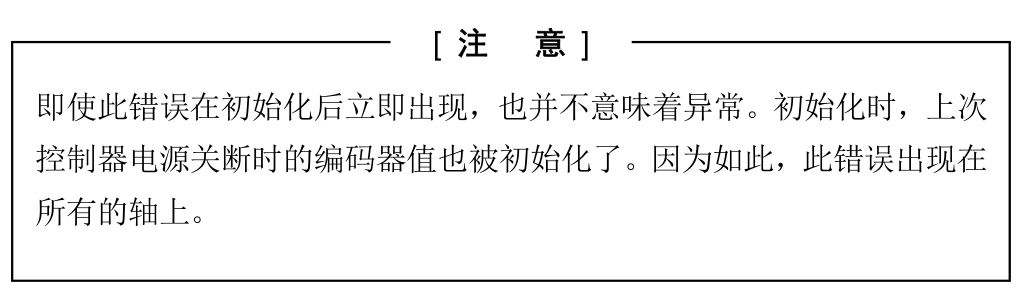
[NOTE]
Even if this error occurs immediately after initialization, it does not indicate an abnormality. During initialization, the encoder values from the last time the controller power was turned off are also initialized. This is why this error occurs on all axes.
Main causes:
-
Encoder internal data has been lost due to depletion of the encoder backup battery, an open circuit in the encoder harness, a faulty encoder, an open circuit in the separate harness, etc.
-
If the controller power is turned OFF during robot operation because of an abnormal power supply or similar condition, the arm will not stop immediately. This creates a difference between the previous encoder value recorded by AS software and the current value at the actual stopping position.
-
Initialization was performed. (This error appears on all axes.)
-
The motor or encoder was replaced.
-
The arm (motor) was forcibly moved while the controller power was OFF.
Countermeasures:
- Perform zeroing immediately after replacing/reinstalling the motor or encoder, or disconnecting the harness.
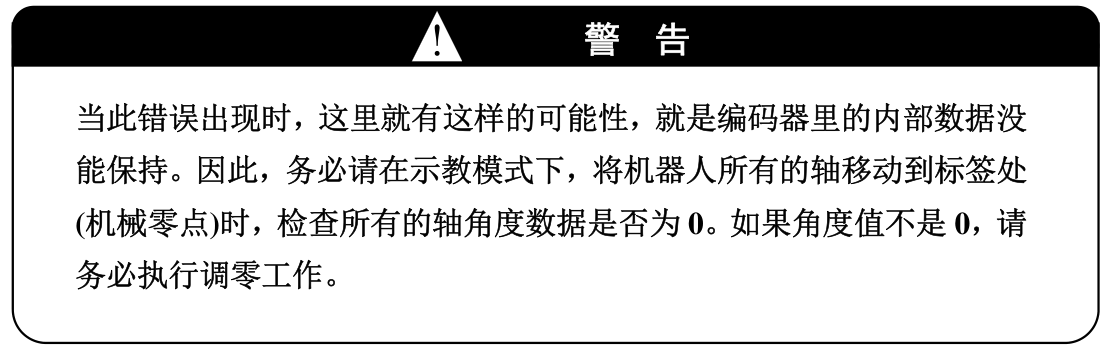
WARNING
When this error occurs, the internal data in the encoder may not have been retained. Therefore, in teach mode, be sure to move all robot axes to their marks (mechanical zero) and check that all axis angle values are 0. If the angle values are not 0, be sure to perform zeroing.
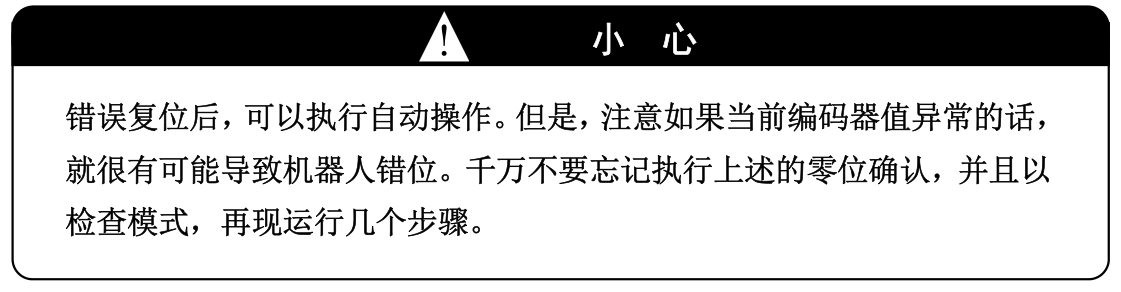
CAUTION
Automatic operation is possible after the error is reset. However, abnormal current encoder values are very likely to cause robot misalignment. Be sure to perform the zero-position check described above and run several steps in check mode.
-
Check the encoder backup batteries and replace them promptly if the voltage drops to +3.3V or lower. Replace encoder batteries for all axes (including the conveyor) at the same time.
-
Check the encoder harness for an open or short circuit and replace it if necessary.
-
Replace the encoder, encoder battery backup board, etc.