Error handling: Motor power OFF.
Error reset: Possible.
Description: The encoder revolution count obtained from carry/borrow operations differs from the revolution count supplied by the encoder magnetic sensor by 1 or more revolutions. (Corresponds to the PS error bit from the encoder.)
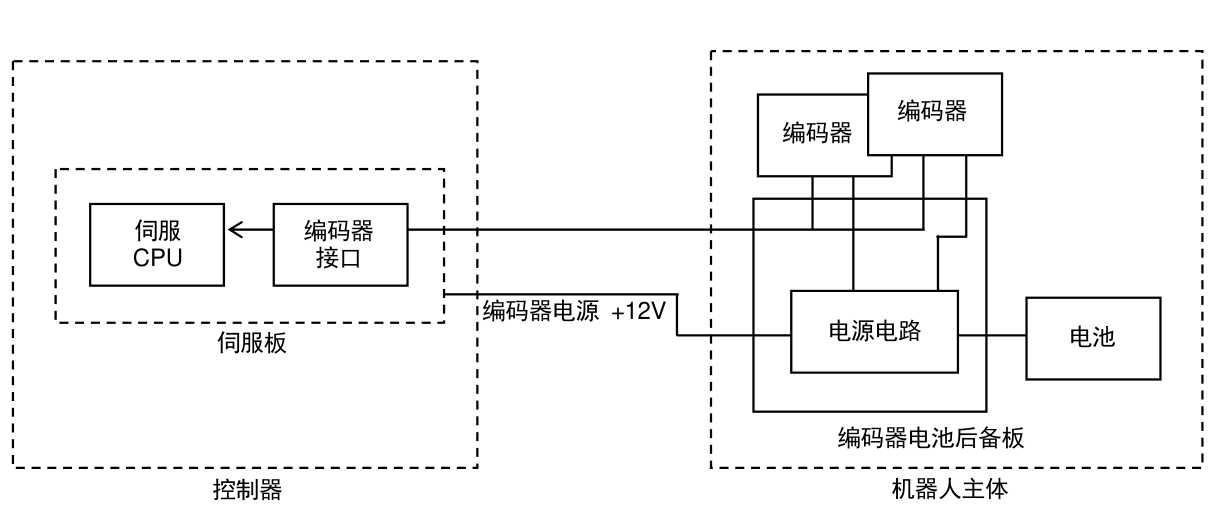
Encoder
Encoder
Servo
Encoder
CPU
Interface
Encoder power supply +12V
Power supply circuit
Battery
Servo board
Encoder battery backup board
Robot main body
Controller
Main causes:
- The encoder is faulty.
Countermeasures:
- Replace the encoder.
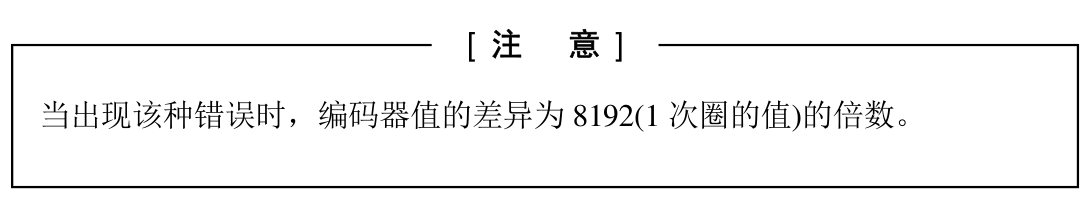
[NOTE]
When this type of error occurs, the difference in encoder values is a multiple of 8192 (the value for 1 revolution).