Cause:
In external mode, the load-and-run signal and run signal are supplied simultaneously.
Troubleshooting:
Check whether the load-and-run signal and run signal in the system signals received rising edges simultaneously.
Solution:
Only one of these two signals can be triggered at the same time. Select either the load-and-run signal or the run signal as needed.
Case sharing:
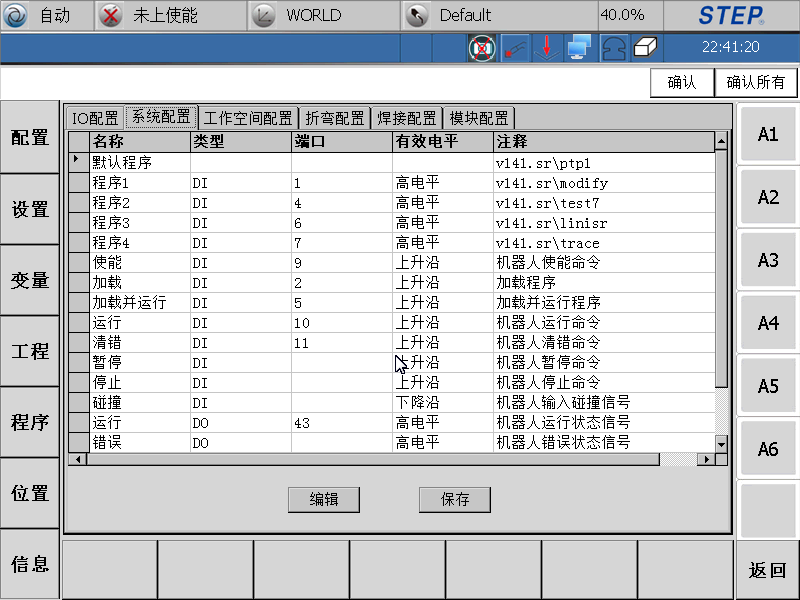
| Name | Type | Port | Active level | Comment |
|---|---|---|---|---|
| Default program | v141.sr\ptp1 | |||
| Program1 | DI | 1 | High level | v141.sr\modify |
| Program2 | DI | 4 | High level | v141.sr\test7 |
| Program3 | DI | 6 | High level | v141.sr\linisr |
| Program4 | DI | 7 | High level | v141.sr\trace |
| Enable | DI | 9 | Rising edge | Robot enable command |
| Load | DI | 2 | Rising edge | Load program |
| Load and run | DI | 5 | Rising edge | Load and run program |
| Run | DI | 10 | Rising edge | Robot run command |
| Clear errors | DI | 11 | Rising edge | Robot clear-error command |
| Pause | DI | Rising edge | Robot pause command | |
| Stop | DI | Rising edge | Robot stop command | |
| Collision | DI | Falling edge | Robot collision input signal | |
| Run | DO | 43 | High level | Robot running status signal |
| Error | DO | High level | Robot error status signal |
If system signals are configured as shown above, with the load-and-run signal assigned to port 5 and the run signal assigned to 10, then in external mode, simultaneously changing DI5 and DI10 from low to high, that is, issuing rising edges to DI5 and DI10 simultaneously, reports error 4022.