Error handling: Motor power OFF.
Error reset: Possible.
Description: Depending on the robot arm posture, excessive direct current may flow through one of the motor's three phases. If this condition continues, wires may burn out even if a motor overload does not occur.
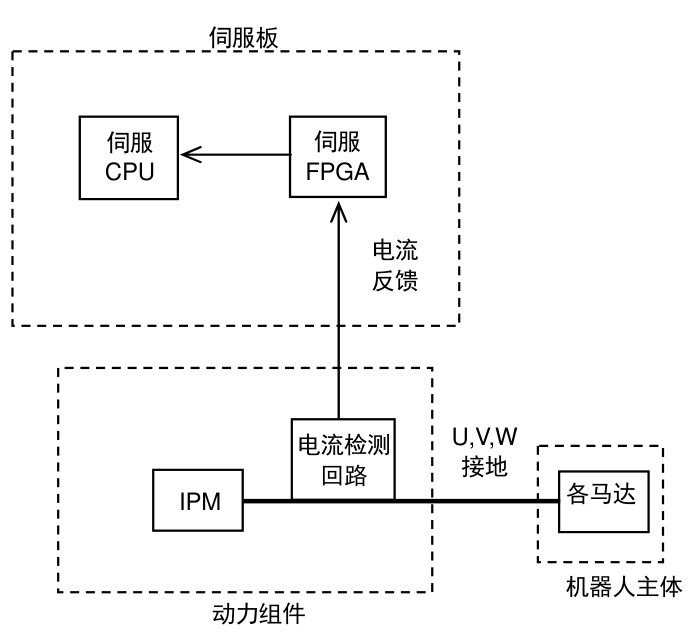
Servo board
Servo
Servo
FPGA
CPU
Current
Feedback
U,V,W
Current detection
Ground
Circuit
Each motor
IPM
Robot main body
Power block
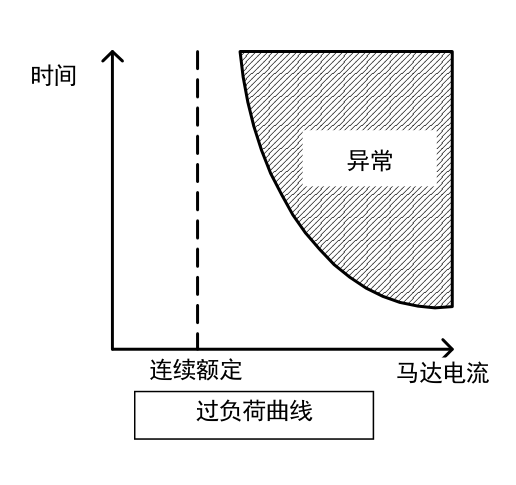
Time
Abnormal
Continuous rating
Motor current
Overload curve
Main cause: The robot remains stationary in a fixed pose for a certain time with the servo ON.
Countermeasures:
-
Change the teaching to reduce the load on the axis where the error occurs. (Avoid teaching that causes an overload, such as keeping the robot in a horizontal posture while holding a workpiece.)
-
When stopping and holding the robot pose for a period of time, turn the servo OFF or enable the automatic servo OFF function.