Error handling: Motor power OFF.
Error reset: Possible.
Description: The robot has moved outside its motion (working) range (restricted space) and activated the axis limit switch.
The motion range of each axis can be set in auxiliary function 0507. It is normally set to the robot's maximum motion range at shipment.
Consider the following conditions when changing the motion range settings:
Operating range > mechanical stopper > axis limit switch > set motion range (restricted space).
Mechanical stops and axis limit switches are optional, and the axes on which they are installed vary with the robot type and configuration. Typically, the AS software limits robot motion to prevent it from exceeding the set working range.
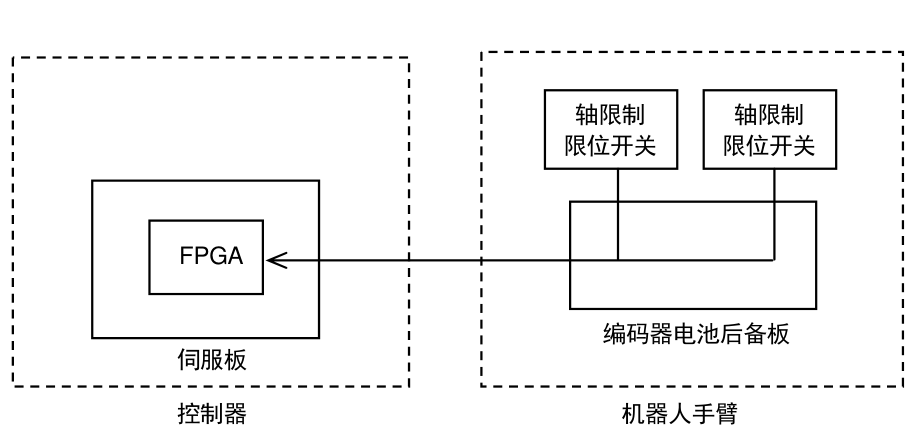
Axis limit
Axis limit
Limit switch
Limit switch
FPGA
Encoder battery backup board
Servo board
Controller
Robot arm
Main causes:
-
Incorrect zeroing data, manual brake release, etc. caused the robot to move outside its operating range (restricted space), and the axis restriction limit switch turned ON.
-
The working range was set to a value greater than the current value while the axis limit switch was ON.
-
The axis limit switch harness has an open circuit while the robot is outside the set working range.
-
If the set working range is close to the axis limit switch installation angle, robot overshoot may turn the limit switch ON.
-
The axis restriction limit switch harness has an open circuit or similar fault.
-
A problem with the servo board.
Countermeasures:
-
When this failure occurs, motor power can be forcibly switched on by holding down the bypass switch on the power sequence board. Then return the arm to within the motion range in teach mode.
-
Alternatively, if the power cannot be turned ON, use the manual brake release switch (option) to release the brakes manually and move the arm into the motion range. At this time, be sure to turn the motor power OFF and release all emergency stop buttons.
-
Set an appropriate motion range value.
-
Adjust the axis limit switch position appropriately.
-
Check the harness and axis limit switches, and replace them if necessary.
-
Replace the servo board.