Cause:
In external mode, a load signal was given while the robot was running.
Troubleshooting:
Check whether a load signal is triggered while the program is running.
Solution:
Do not give a load signal while the program is running. To reload the program, give the load signal after the program is paused or stopped.
Case sharing:
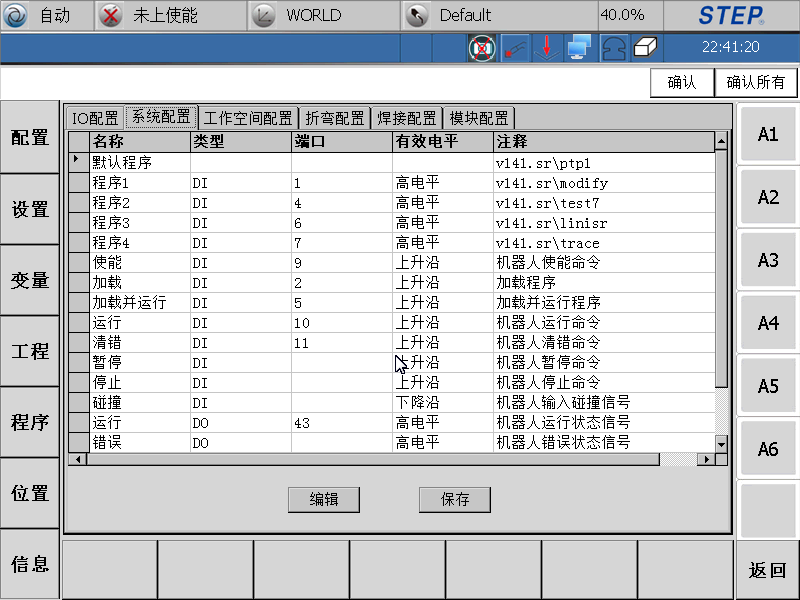
| Name | Type | Port | Active level | Comment |
|---|---|---|---|---|
| Default program | v141.sr\ptp1 | |||
| Program1 | DI | 1 | High level | v141.sr\modify |
| Program2 | DI | 4 | High level | v141.sr\test7 |
| Program3 | DI | 6 | High level | v141.sr\linisr |
| Program4 | DI | 7 | High level | v141.sr\trace |
| Enable | DI | 9 | Rising edge | Robot enable command |
| Load | DI | 2 | Rising edge | Load program |
| Load and run | DI | 5 | Rising edge | Load and run program |
| Run | DI | 10 | Rising edge | Robot run command |
| Clear errors | DI | 11 | Rising edge | Robot clear-error command |
| Pause | DI | Rising edge | Robot pause command | |
| Stop | DI | Rising edge | Robot stop command | |
| Collision | DI | Falling edge | Robot collision input signal | |
| Run | DO | 43 | High level | Robot running status signal |
| Error | DO | High level | Robot error status signal |
If the system signals are configured as shown above, issuing another rising edge to load signal DI2 while the robot is running in external mode reports error 4006. To reload a program, issue a pause or stop signal first, then the load signal.