Error handling: Motor power OFF.
Error reset: Possible.
Description: For equipment with a transformer unit, a thermostat contact inside the arm connected to the thermostat wiring in the motor harness (X4 harness) is activated, the harness has an open circuit, or the transformer thermostat is activated.
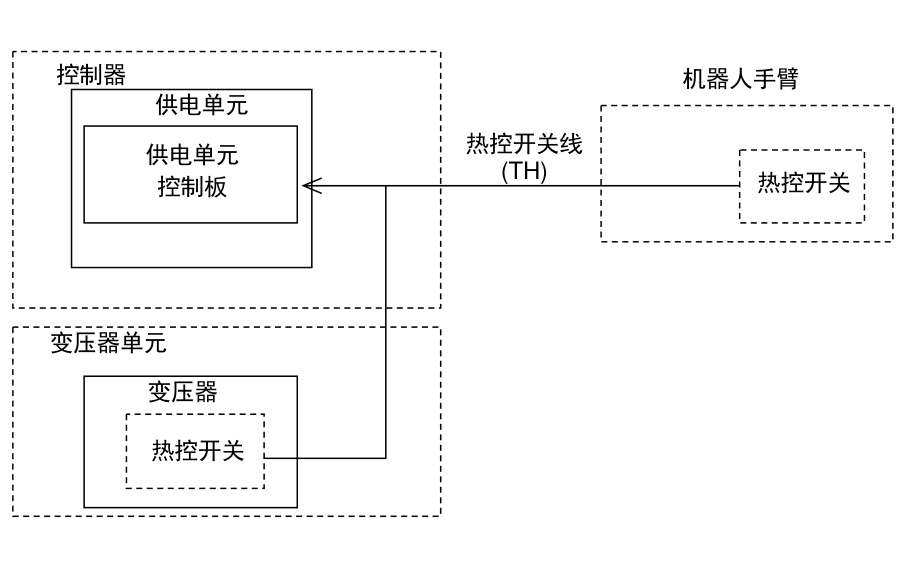
Controller
Robot arm
Power supply unit
Thermal switch wiring
Power supply unit
(TH)
Thermal switch
Control board
Transformer unit
Transformer
Thermal switch
Main causes:
-
An open circuit in the thermostat wiring inside the arm.
-
An open circuit or poor connection between the separation harness (X4 cable) and transformer unit - controller harness (XTRFAN cable).
-
The harness at X314 on the power supply unit control board has an open circuit or poor connection.
-
The thermostat inside the transformer unit is activated.
(1) The transformer unit fan has stopped.
(2) The robot ambient temperature exceeds the allowable operating ambient temperature range.
(3) Intense robot motions were performed continuously.
-
A problem with the brake power supply (DC26V).
-
A problem with the power supply unit control board.
-
A thermal switch is built into the robot arm.
(1) An overload or similar error has just occurred.
(2) Excessive load was applied to the robot, exceeding its load capacity.
(3) The robot ambient temperature exceeds the allowable operating ambient temperature range.
(4) Severe robot motions, such as reverse taught motion, are being performed continuously.
(5) The servo system operated continuously for a long period with the arm in a high-load pose.
(6) A problem with the thermostat.
Countermeasures:
-
Check the thermal switch wiring between the X314 connector on the power supply unit control board and the transformer unit or arm.
-
Replace the power supply unit control board.
-
If there is a problem with the brake power supply, refer to "E1337".
-
Check the operating conditions, and use the robot within its rated range.
-
Check whether the transformer unit fan operates.
-
Recheck the robot motion.
-
If a production line stoppage causes the servo system to remain active for a long time with a high arm load, release the robot from interlocks or similar states and place it in HOLD (pause), or set [Automatic servo OFF time] in auxiliary function 0808.