Error handling: Motor power OFF.
Error reset: Possible.
Content: A cyclic redundancy check (CRC) or framing abnormality was detected in communication with the encoder.
CRC abnormality: A cyclic redundancy check code is appended to the encoder communication data, and an abnormality is detected during calculation using the generator polynomial. Framing abnormality: No stop bit was detected in the encoder data.
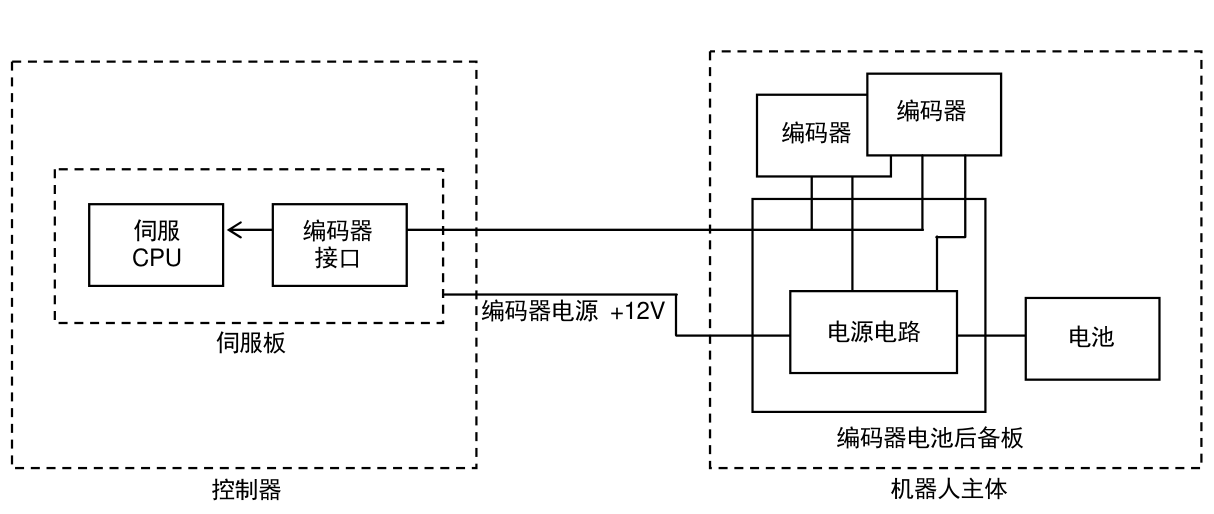
Encoder
Encoder
Servo
Encoder
CPU
Interface
Encoder power supply +12V
Power supply circuit
Battery
Servo board
Encoder battery backup board
Robot main body
Controller
Main causes:
-
Noise interference. (Noise is more likely if the error occurs only while the robot servo is on.)
-
A problem with the encoder.
-
A problem with the servo board.
Countermeasures:
-
Check the noise immunity of the encoder wiring (cable shielding).
-
Replace the encoder.
-
Replace the servo board.
[NOTE]
After resetting the error, run the robot program at low speed in repeat mode, or carefully operate the robot manually in teach mode.